Kefeng Huang 黄克峰
kefhuang AT outlook.com
I am currently a PhD student at the Robot Assisted Living Lab, University of York, as part of the ALBERT Centre for Doctoral Training, supervised by Dr. Jihong Zhu, Prof. Andy Tyrrell and Prof. Ian J.S. Fairlamb. I was a research intern at Tencent Robotics X, supervised by Dr. Tingguang Li. I obtained my bachelor's and master's degrees with first-class honours in Computer Science at UCL, supervised by Prof. Jun Wang.
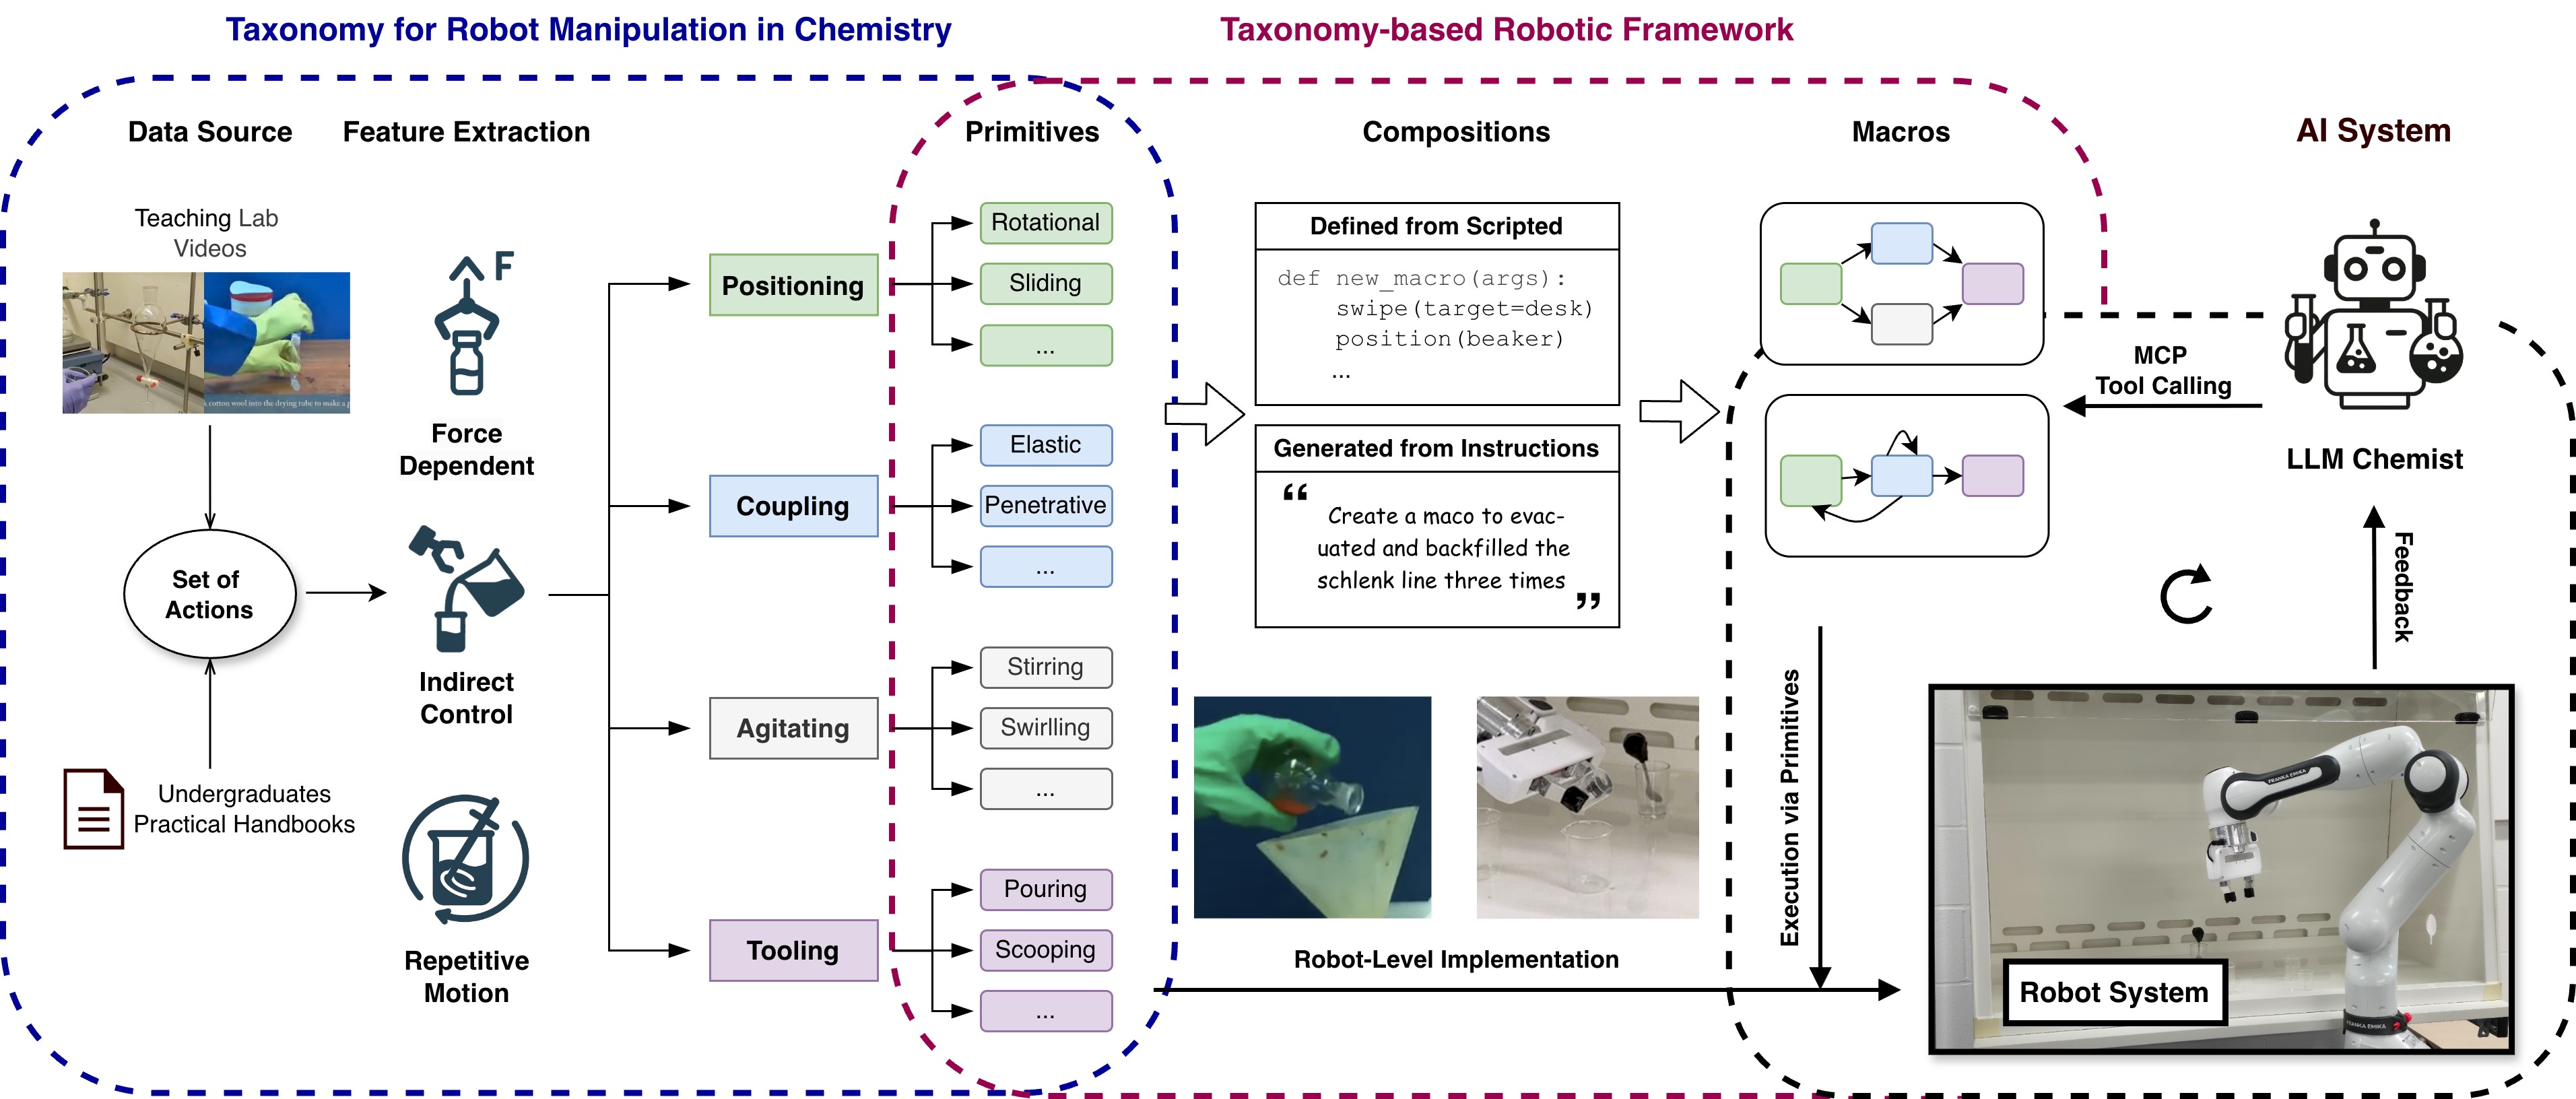
My research lies at the intersection of robot learning and laboratory automation, with a focus on robotic manipulation for chemistry. I am interested both in developing new robot learning methods for laboratory tasks and in deploying robotic systems in real chemistry labs. Currently, I am working towards a robot chemist that carries out chemistry experiments alongside human chemists.Updates
Nov 2026Our TARMAC paper is featured on the Communications Chemistry homepage.
Nov 2026DeepTech (深科技) published a Chinese article introducing TARMAC.
Nov 2026Our paper TARMAC has been published in Communications Chemistry.
Mar 2026Our poster has been awarded a Poster Prize from Digital Discovery by the Royal Society of Chemistry.
Aug 2025Our poster has won the Unitree Award for Best Poster at TAROS 2025.
Nov 2024I joined the University of York as a PhD student
May 2024I started as a research intern at Tencent Robotics X
Publications
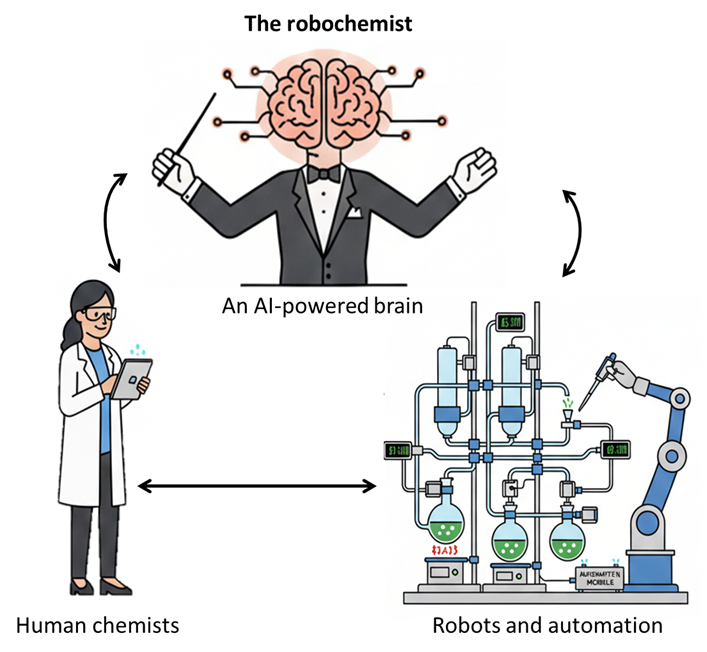
Rise of the Robochemist
Jihong Zhu, Kefeng Huang, Jonathon Pipe, Chris Horbaczewsky, Andy Tyrrell, and Ian J. S. FairlambeNewsletter of the IEEE SMC Society, Issue 86, September 2025
Awards
- Poster Prize from Digital Discovery - Royal Society of Chemistry (2026)
- The Unitree Award for Best Poster on Autonomous Systems for Laboratory Experiments - TAROS (2025)
- Gold Award at UK Chemistry Olympiad - Royal Society of Chemistry (2019)
Patents
- 机器人控制及模型训练方法、装置、设备及存储介质李珽光, 刘宇真, 黄克峰Chinese Patent No: CN119304873A | Status: Under Review | Date: 2024
Teaching
- COMP0037 Robotic System - Teaching Assistant at UCL
- COMP0128 Robotic Control Theory and Systems - Teaching Assistant at UCL
- COMP0129 Robotic Sensing, Manipulation and Interaction - Teaching Assistant at UCL
- COMP0202 Mathematics for Robotics and AI - Teaching Assistant at UCL